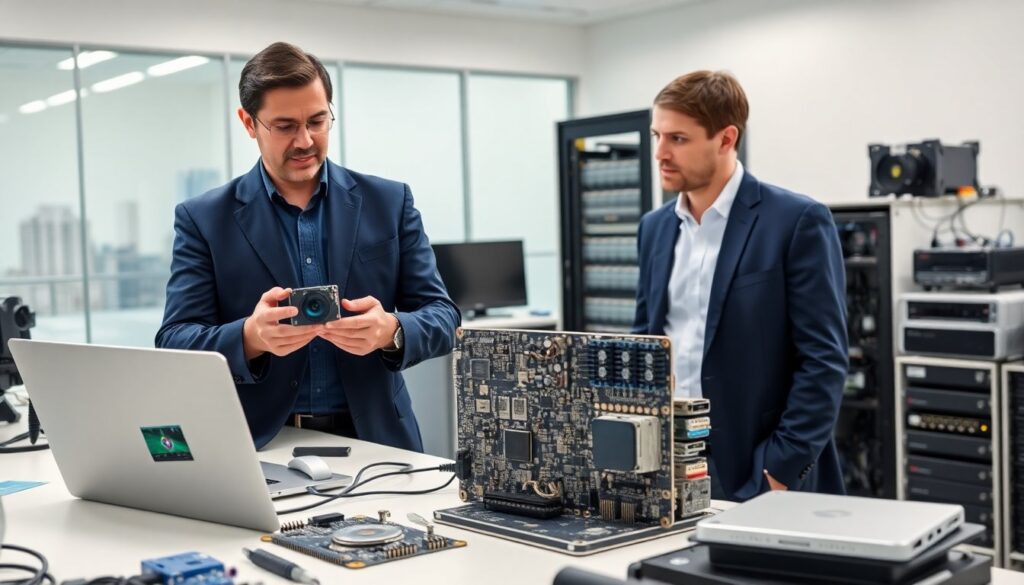
cameras machine learning processor motherboard etcelrootherx appears in many modern imaging projects. The phrase defines the main components that engineers choose when they build smart camera systems. This guide explains camera module choices, on-device ML processor options, and motherboard integration steps. It gives clear, practical advice readers can use to pick parts and assemble a working device in 2026.
Key Takeaways
- Choosing the right camera module is critical for machine learning accuracy, with sensor type, resolution, lens, and filters tailored to the application and environment.
- Selecting an on-device machine learning processor requires balancing power, latency, and model support, with options like Edge TPUs, NPUs, and GPUs suited for different inference needs.
- Compatibility and performance profiling of ML models on processors ensure efficient real-time inference and adherence to thermal and power budgets.
- Motherboard design must integrate camera modules and ML processors carefully, managing connectors, power distribution, cooling, and memory for optimal system reliability.
- A secure and optimized software stack encompassing drivers, pipelines, and secure boot is essential to enable smooth camera-to-inference workflows and protect the device.
- Rigorous testing under varied conditions helps refine hardware and software choices to meet performance and reliability targets in smart camera systems.
Choosing The Right Camera Module For Machine Learning Applications
Camera selection shapes the data that a model learns from and the performance users will see. Engineers pick a sensor first. They select between global-shutter and rolling-shutter sensors. They choose global-shutter sensors for fast motion and rolling-shutter sensors for lower cost. They match sensor resolution to the task. They pick higher resolution for object detection at distance. They use lower resolution to save bandwidth and processor cycles.
Designers examine lens options next. They pick fixed-focus lenses for simple tasks. They pick autofocus lenses when subjects vary in distance. They choose wide-angle lenses for room monitoring. They pick telephoto lenses for long-range inspection. They check modulation transfer function (MTF) and distortion numbers when image quality matters.
Engineers add filters and infrared support when lighting is poor. They pick IR-cut filters for color accuracy in daylight. They enable IR sensitivity for night operation. They choose global shutter plus IR for industrial inspection with active lighting.
They consider interface and bandwidth. They pick USB3 or MIPI CSI-2 based on the motherboard connector and desired throughput. They check the camera frame rate at target resolution. They budget for raw formats or compressed output. They confirm the camera driver support for the chosen operating system.
Teams test cameras with sample data. They record real scenes that match production conditions. They train or validate models on those samples. They then iterate camera settings, lens choice, and filters until the data quality meets performance targets. The team repeats this process when they switch ML processors or motherboards to maintain consistent accuracy.
Selecting An On‑Device Machine Learning Processor: Edge TPUs, NPUs, And GPUs
They select an ML processor to run inference on the device. They compare Edge TPUs, NPUs, and GPUs for power, latency, and model support. They pick Edge TPUs for low power and fast quantized inference. They pick NPUs when vendors provide optimized runtimes and wide operator support. They pick GPUs when models require large tensors or mixed precision.
Teams verify model compatibility next. They convert models to supported formats such as TFLite for Edge TPUs or ONNX for NPUs and GPUs. They run unit tests to confirm operator parity. They profile latency and memory use on candidate processors. They measure real input-to-output time with the chosen camera and a typical scene.
They measure power draw during peak inference. They select processors that meet the device thermal budget. They choose processors with dynamic voltage and frequency scaling when power varies. They prefer processors with hardware accelerators for convolution and matrix math to shorten inference times.
They assess software ecosystems. They pick vendors that provide reliable SDKs, driver updates, and optimizer tools. They test quantization tools and accuracy drops. They consider model sparsity and pruning tools when memory is tight.
Teams plan for future models. They select processors with headroom for larger models or new operators. They verify that the chosen processor supports real-time batching or pipelining. They document the decision and repeat profiling after firmware updates or model changes.
Motherboard And Integration Considerations For Camera + ML Systems
They design the motherboard to connect camera modules and ML processors reliably. They map connectors early. They place MIPI CSI-2 lanes near the processor to avoid high-speed trace runs. They route differential pairs carefully and follow the processor datasheet. They include level shifters when interfaces use different voltages.
They plan cooling and power distribution. They specify heatsinks or active fans for high-power processors. They design power planes to avoid voltage drop under peak load. They add monitoring points for voltage and temperature to the board layout.
They allocate memory and storage based on model needs. They add high-bandwidth LPDDR for models that stream large tensors. They choose eMMC or NVMe storage when they need fast model load times. They size flash for logs, model versions, and edge updates.
They build a software stack that ties camera, processor, and OS together. They install drivers for the camera sensor and the ML accelerator. They carry out a pipeline that captures frames, preprocesses images, runs inference, and handles postprocessing. They optimize memory copies and use zero-copy paths when possible.
They secure the device. They enable secure boot and sign firmware images. They encrypt models at rest and enforce access controls for model updates. They add a secure element when they need hardware-backed key storage.
They test the full system under expected conditions. They evaluate end-to-end latency from camera exposure to inference output. They test the system under varied lighting, temperature, and network conditions. They log results and iterate on hardware layout, cooling, and software to meet reliability targets.